Search Results for 'robot joint'

robot joint published presentations and documents on DocSlides.
ROBOT SENSORS AND ROBOT VISON
by marina-yarberry
T. . Bajd. and M. . Mihelj. Proprioceptive senso...
Optimizing actuation for a legged robot
by pamella-moone
Motors, transmissions, linkages, & springs. R...
Robotic Arm Challenge Dr.
by leah
Parshati. Patel and Sarah Simpson. Robotic Arm. A...
ACTUATORS Actuators are the devices which provide the actual motive force for the robot joints.
by tatiana-dople
Actuators are the muscles of robots. If you imagi...
BIPED ROBOT
BIPED ROBOT
by celsa-spraggs
Introduction. Designing controllers for walking r...
Introduction
Introduction
by debby-jeon
To. Robotics. By. . Ed Red. “A robot is a re-...
Robot Modeling and the Forward Kinematic Solution
by briana-ranney
ME . 4135. Lecture Series . 4. Dr. R. Lindeke –...
Inverse Kinematics Kris
by natalia-silvester
Hauser. CS B659: Principles of Intelligent Robot ...
Space Robotics Presented
by trish-goza
by. Mahesh . Babu.S. IV-. Btech. Electronics and ...
Problem Definition Experimental Results
by cecilia
Tuning of the Feedback Parameters. Fused Angle Fee...
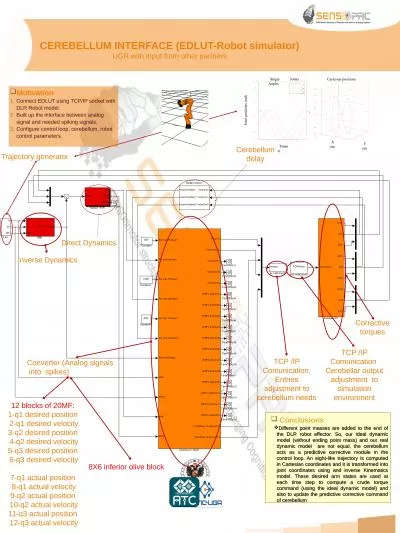
CEREBELLUM INTERFACE (EDLUT-Robot
by byrne
simulator. ). UGR . with. input . from. . other....
International Journal of Artificial Intelligence  Applications IJAIA
International Journal of Artificial Intelligence Applications IJAIA
by jaena
International Journal of Artificial Intelligence &...
rrnrrnJaKa Zu Collaborative RobotnrrnrnnnrrnrrOSWindowsrrrrnC language
by trinity
ZC8yixtiy8xndnFy8mtnMiixiI88gndtbi8888888888888888...
Xemo Player’s Guide
Xemo Player’s Guide
by caroline
1.7 – September 2017
Intro  to  Movement of robots and introduction to kinematics of robots
Intro to Movement of robots and introduction to kinematics of robots
by alida-meadow
Kinematics: . constraints on getting around the ...
Introduction to Robotics
by test
Robot.  ”programmable, multifunction, manipula...
Big Dog  By  Z ack  Tippie
Big Dog By Z ack Tippie
by celsa-spraggs
and Matt . S. parks. Big dog is used as a pack m...
Introduction to Robotics
by min-jolicoeur
cpsc. - 460. Textbook. Robot Modeling and Contr...
NMT EE 589 & UNM ME 482/582
by calandra-battersby
Robot Engineering. Dr. Stephen Bruder. NMT EE 589...
Problem Definition
Problem Definition
by alexa-scheidler
Experimental Results. Tuning of the Feedback Para...
Control Design to Achieve Dynamic Walking
by jane-oiler
on a Bipedal Robot with Compliance. Young-. Pil. ...
Control Design to Achieve Dynamic Walking
by tatiana-dople
on a Bipedal Robot with Compliance. Young-. Pil. ...
Forward
Forward
by celsa-spraggs
Kinematics and Configurations. Kris Hauser. I400/...
Exoskeleton
Exoskeleton
by faustina-dinatale
. Robot. . for. . Rehabilitation. . o. f. . ...
Journal of Robotics and Control JRC
by jaena
Volume 2 , Issue 4 , July 202 1 ISSN: 2715 - 5...
Universal Robots
Universal Robots
by margaret
A/S Energivej 25 DK - 5260 Odense S CVR - nr. 29 ...
Advanced Mako RoboticArm Assisted Surgery
by davies
MEET MAKOIs your quality of life less than ideal b...
Path Control in Robotics
by alida-meadow
ME 4135. Richard . R. Lindeke, Ph. D.. Motion Typ...
DIFFERENTIAL KINEMATICS
by celsa-spraggs
. Purpose:. The purpose of this chapter is to in...
GEOMETRIC DESCRIPTION OF
by calandra-battersby
THE ROBOT MECHANISM. T. . Bajd. and M. . Mihelj....
Path Control in Robotics
by test
ME . 4135, F 2012. Richard . R. Lindeke, Ph. D.. ...
DIFFERENTIAL KINEMATICS Purpose: The purpose of
by danika-pritchard
DIFFERENTIAL KINEMATICS Purpose: The purpose of th...
Learning Agile and Dynamic Motor Skills for Legged Robots
by KissableLips
Jemin. . Hwangbo. , . Joonho. Lee, Alexey . Doso...
RoboticsandAutonomousSystems3620013751
by miller
Acquisitionofstand-upbehaviorbyarealrobotusinghier...
RoboticsandAutonomousSystems3620013751
by callie
Acquisitionofstand-upbehaviorbyarealrobotusinghier...
by reflecting the impact of control actions at the interface on actual
by adia
Variance (ANOVAs) of interface design, control mod...
Dynamics  of Articulated Robots
Dynamics of Articulated Robots
by luanne-stotts
Kris Hauser. CS B659: Principles of Intelligent R...
Dynamics  of Articulated Robots
Dynamics of Articulated Robots
by ellena-manuel
Kris . Hauser. ECE 383 / ME 442. Spring 2015. Age...
Intuitive Kinematics – Converting Between Forward and Reverse Definitions of Space
by alexa-scheidler
Lecture Series 2. ME 4135 . R. R. Lindeke. Intui...
College of Engineering and Applied Sciences
by karlyn-bohler
Mechanical Engineering Department . Motion Contro...